
Estimated reading time: 10 minutes
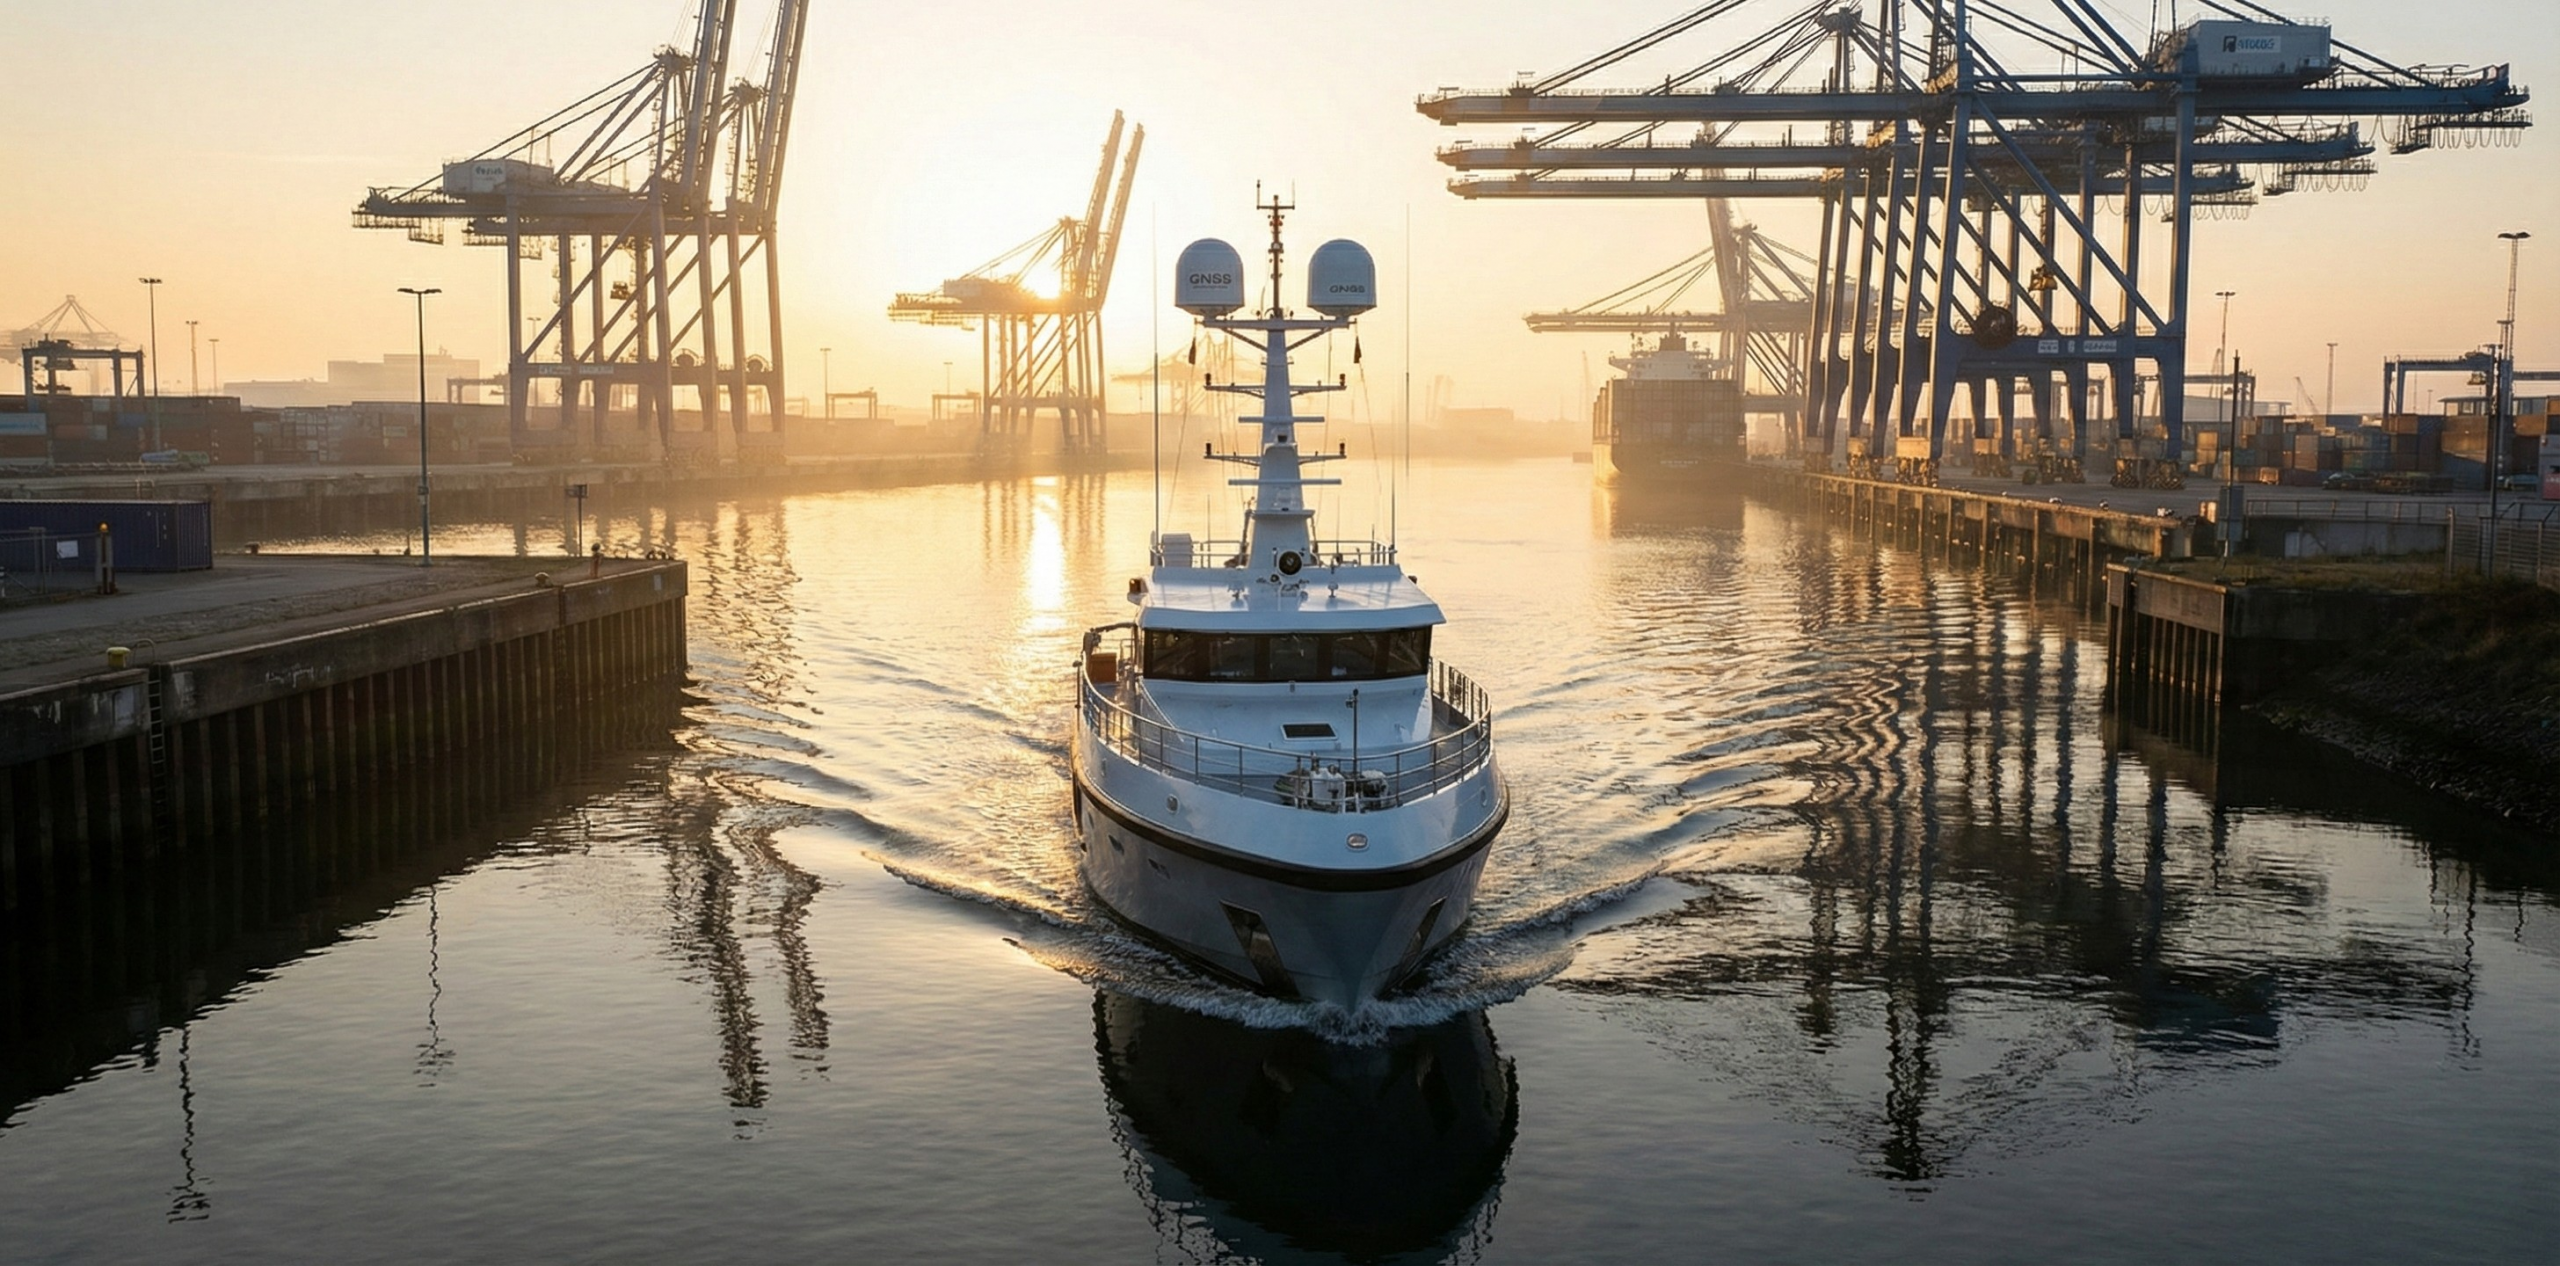
For maritime transportation - vessel navigation, port automation, and waterway surveys - water-surface reflections create a unique multipath environment requiring sensor fusion rather than GNSS tuning alone.
Table of contents
- Summary
- Key takeaways
- Overview of Real-Time Kinematic (RTK) Positioning
- How marine multipath differs from urban multipath
- Challenges of Multipath Propagation in Marine Settings
- The accuracy the job actually demands
- Solutions to Mitigate Multipath Interference
- Keeping corrections healthy on a vessel underway
- Impact of Sensor Fusion on Navigation Accuracy
- RTKdata for Maritime
- FAQ
Start your 30-day free trial
Test pro-grade RTK corrections on your waters. Validate RTK Fix, correction age, and workflow with your own equipment.
Summary
Maritime multipath (reflections from water, metal, docks, bridges) can make RTK positions jump or lag, especially during docking and tight turns. Combining multi-frequency GNSS with tightly-coupled INS, robust filtering, and good antenna practice keeps vessels on course with cm-level accuracy when conditions allow.
Key takeaways
- RTK + sensor fusion holds cm-level positioning in ports and channels when correction age stays low and sky view is managed.
- Multipath from water and structures is the main marine challenge; it can cause jumps, lags, and re-initialisations.
- Mitigation splits in two: what you set on the boat (multi-frequency, multi-constellation, elevation mask, antenna height) and what the receiver does for you (multipath estimation such as MEDLL).
- Calm water is the harder case. A smooth surface returns a coherent delayed signal; chop scatters it into noise.
- Carrier-phase multipath is bounded near 5 cm on L1. Code and non-line-of-sight errors are not, which is why a Fix is lost at re-acquisition rather than eroded slowly.
- Tightly-coupled GNSS/INS bridges dropouts and smooths multipath, provided the system is calibrated and logs are monitored.
Overview of Real-Time Kinematic (RTK) Positioning
RTK uses base/network corrections with carrier-phase measurements to reach cm-level accuracy. In busy ports and narrow channels, RTK multipath sensor fusion blends GNSS with IMU/INS so the vessel maintains a stable solution even when satellites are blocked or reflections rise. Across maritime transportation, from vessel navigation to port automation and waterway survey work, that pairing is what keeps a position usable once the environment stops cooperating.
How marine multipath differs from urban multipath
Ashore, the reflectors stand beside you: walls, vehicles, canopy. At sea the geometry inverts. The dominant reflector is a large, near-horizontal surface directly beneath the antenna, and the second is the vessel you are standing on. A review by Collins Aerospace, University College London and NASA notes that for air, sea and space applications, "reflections off the host-vehicle body are more common" than reflections from the surrounding environment (McGraw, Groves and Ashman, retrieved August 2026).
Material matters as much as geometry. The same review reports that "calm water, metal, and metallized glass can produce particularly strong specular reflections with reflection coefficients of 0.5-0.7", where brick, stone and concrete sit lower. Open water reads as the easy environment because the sky is clear, and on reflection strength it is the harder one. That is why this article stays on the water; cities, forests and inland sites fail differently, and we cover them in our piece on RTK multipath on land.
Why a flat calm is the harder case
Sea state decides which failure mode you get, and not the way most crews expect. Roughness is judged against the signal wavelength, roughly 0.2 m for GNSS. A surface rough on that scale scatters the signal in many directions, which the receiver sees as extra noise. A surface that is "smooth and of sufficient size" produces specular reflection instead: one strong copy, returned at an angle equal and opposite to the incoming signal. Chop lifts the noise floor; glassy water hands the antenna a clean, coherent, delayed copy, and a coherent copy is what biases a measurement.
Challenges of Multipath Propagation in Marine Settings
Reflections from water, metal decks, docks, bridges, or cranes arrive late and bias measurements. Superstructures shadow satellites; storms and tall shores cut visibility. Radios and other gear add RF noise. The result: more cycle slips, longer convergence, and unstable Fix, exactly when precision matters most.
What that does to an RTK solution is not uniform, and the distinction is the useful part. Carrier-phase multipath is bounded: ESA's Navipedia puts the ceiling at "a quarter of the wavelength", about 5 cm on GPS L1 or L2 and typically under 1 cm (retrieved August 2026). The Collins, UCL and NASA review reaches 4.8 cm on L1 independently. Code multipath has no such ceiling, and for non-line-of-sight reception the review calls the errors "potentially unbounded and always positive".
So while you hold a Fix, marine multipath costs centimetres. The damage concentrates where the receiver leans on code, meaning acquisition and ambiguity resolution. That matches what crews report: not a position drifting slowly away, but a Fix that will not come back after a turn under a gantry or a slow pass along a steel hull.
The accuracy the job actually demands
The bar is not set by correction vendors. IMO Resolution A.915(22) lists minimum maritime user requirements, and the tiers sit far apart: 10 m horizontal for ocean, coastal and port approach; 1 m for port navigation; and 0.1 m with a 0.25 m alert limit and a 1 second fix interval for automatic docking (retrieved August 2026).
Read that as a scale, not a rule. A.915(22) states requirements for a future GNSS. It is not an equipment mandate and it names no positioning method. The arithmetic still holds: an uncorrected receiver clears 10 m comfortably and cannot reach the decimetre tier, while RTKdata corrections land at 1-2 cm horizontal, 2-3 cm vertical. For the gap in plain terms, see how RTK compares with standard GNSS accuracy. That decimetre tier is also where hydrographic surveying works.
Solutions to Mitigate Multipath Interference
What you set. Use multi-frequency, multi-constellation GNSS (GPS, Galileo, GLONASS, BeiDou) for redundancy and faster ambiguity resolution. Apply an elevation mask that discards the low-elevation signals most likely to arrive off the water. Keep cables and connectors sound, because a marginal connector and a reflection leave the same trace in the log.
What the receiver does. Modern receivers estimate the reflection rather than filter around it. The most widely used family, as Siebert, Konovaltsev and Meurer set out in NAVIGATION, is "the multipath estimating delay locked loop (MEDLL) (van Nee et al., 1994)", which samples the correlation function with a correlator bank and subtracts the estimated replicas before a position is formed (retrieved August 2026). That is a property of the receiver you buy, not a setting you change at sea.
What it is worth. Trimble, describing its own multipath rejection, puts the cost at "many centimeters in RTK positioning and decimeters or more in autonomous, SBAS or DGPS positioning modes", and lists water among the reflectors alongside vehicles, buildings and walls (retrieved August 2026).
Antenna siting on a vessel
Ashore the instruction is to move away from the reflector. Navipedia gives the general form: multipath error is minimised by better antenna quality and by "moving the antenna away from reflecting objects (when possible)". Afloat, that parenthetical is the whole problem, because the reflector is the vessel and the sea beneath it. What is left is height and shielding. Mount above the superstructure rather than beside it, clear of radar scanners and satcom domes. Use a ground plane or choke-ring to reject energy from below, keep the radome and low-loss marine coax in good condition, and treat the deck as a reflector rather than a mounting convenience.
Keeping corrections healthy on a vessel underway
A vessel is a fast rover that crosses network cells inside a single job, which a survey pole or a tractor does not. That changes what you monitor. The RTKdata caster uses the NMEA GGA sentence your receiver sends to pick the nearest reference station, and the network documentation is explicit: "If you move across a coverage area, the system can hand off to a closer station automatically." Without GGA the caster cannot choose at all, so the session connects and the corrections never suit your position.
Three things belong on a bridge display. GGA cadence, because a stale position means a stale base assignment. Correction age, which degrades before the Fix does. And the endpoint: RTKdata publishes regional endpoints rather than one global address, so a European vessel and an Australian one should not point at the same host. If that is unfamiliar, read the NTRIP connection flow before the first sea trial.
Open RTKdata Docs
See setup patterns for NTRIP/RTCM, fusion integration, and quality monitoring (Fix state, correction age, PDOP).
Impact of Sensor Fusion on Navigation Accuracy
Tight coupling lets GNSS provide absolute truth while the INS bridges short gaps, smooths multipath jumps, and stabilises heading. Best practices: keep IMU/GNSS calibration current, verify correction streams and mountpoints, and apply post-mission filtering to clean logs.
At sea, three specifics apply. Heave, roll and pitch put the antenna somewhere other than the hull reference point, so lever arm calibration is real work. Heading cannot come from course over ground when a vessel manoeuvres slowly, which is why dual-antenna and moving-base setups are common afloat. And per the bound above, the INS mainly covers the interval in which the receiver re-resolves ambiguities. Trimble's ProPoint uses "dynamic models tuned to specific applications such as automotive vs off-road vs marine" (retrieved August 2026). For the estimator architecture, see our guide to sensor fusion for robotics localization.
RTKdata for Maritime
RTKdata exposes modern RTK streams and supports fusion workflows for maritime use. Trial real routes, compare configurations, and standardise on what holds cm-level accuracy in your waters.
Plan your maritime deployment
Discuss coverage, accuracy targets, and integrations for ports, channels, and offshore operations, or try live corrections now.
Frequently asked questions
What is RTK multipath sensor fusion?
It pairs RTK corrections with an inertial sensor: RTK gives the absolute centimetre-level fix, the INS carries it through the seconds when reflections or blockage take that fix away.
Why is maritime multipath so problematic?
Water reflects GNSS signals harder than most buildings do. Calm water, metal and metallized glass produce specular reflections with reflection coefficients of 0.5-0.7, where brick, stone and concrete sit lower (McGraw, Groves and Ashman, retrieved August 2026). Add the vessel's own steel and the reflector is something you manage, not something you walk away from.
How can multipath interference be mitigated?
Split it in two. What you control: multi-frequency and multi-constellation tracking, a sensible elevation mask, antenna height above the superstructure, a ground plane, and sound cables. What the receiver controls: multipath estimation in the tracking loops, of which MEDLL (van Nee et al., 1994) is the most widely used family.
How does INS help during outages?
With tight coupling, INS bridges short gaps, smooths multipath jumps and stabilises heading while GNSS re-locks ambiguities. Afloat it also holds heading when a slowly manoeuvring vessel has no usable course over ground, and absorbs heave, roll and pitch between the antenna and the hull reference point.
Which antenna setups reduce marine multipath?
Mount high and clear of the superstructure, away from radar scanners and satcom domes. Add a ground plane or choke-ring against energy arriving from below, and keep radome, marine coax and connectors sound.
In hydrographic surveying, water-surface multipath is one of the most underestimated accuracy risks - tightly-coupled GNSS/INS is essential for reliable positioning on the water.
For multipath challenges in land-based environments - cities, forests, and construction sites - see our companion piece on RTK multipath on land.
The same Kalman filter and tightly-coupled GNSS/INS principles described here apply to land-based autonomous platforms - see our guide on sensor fusion for robotics localization.